



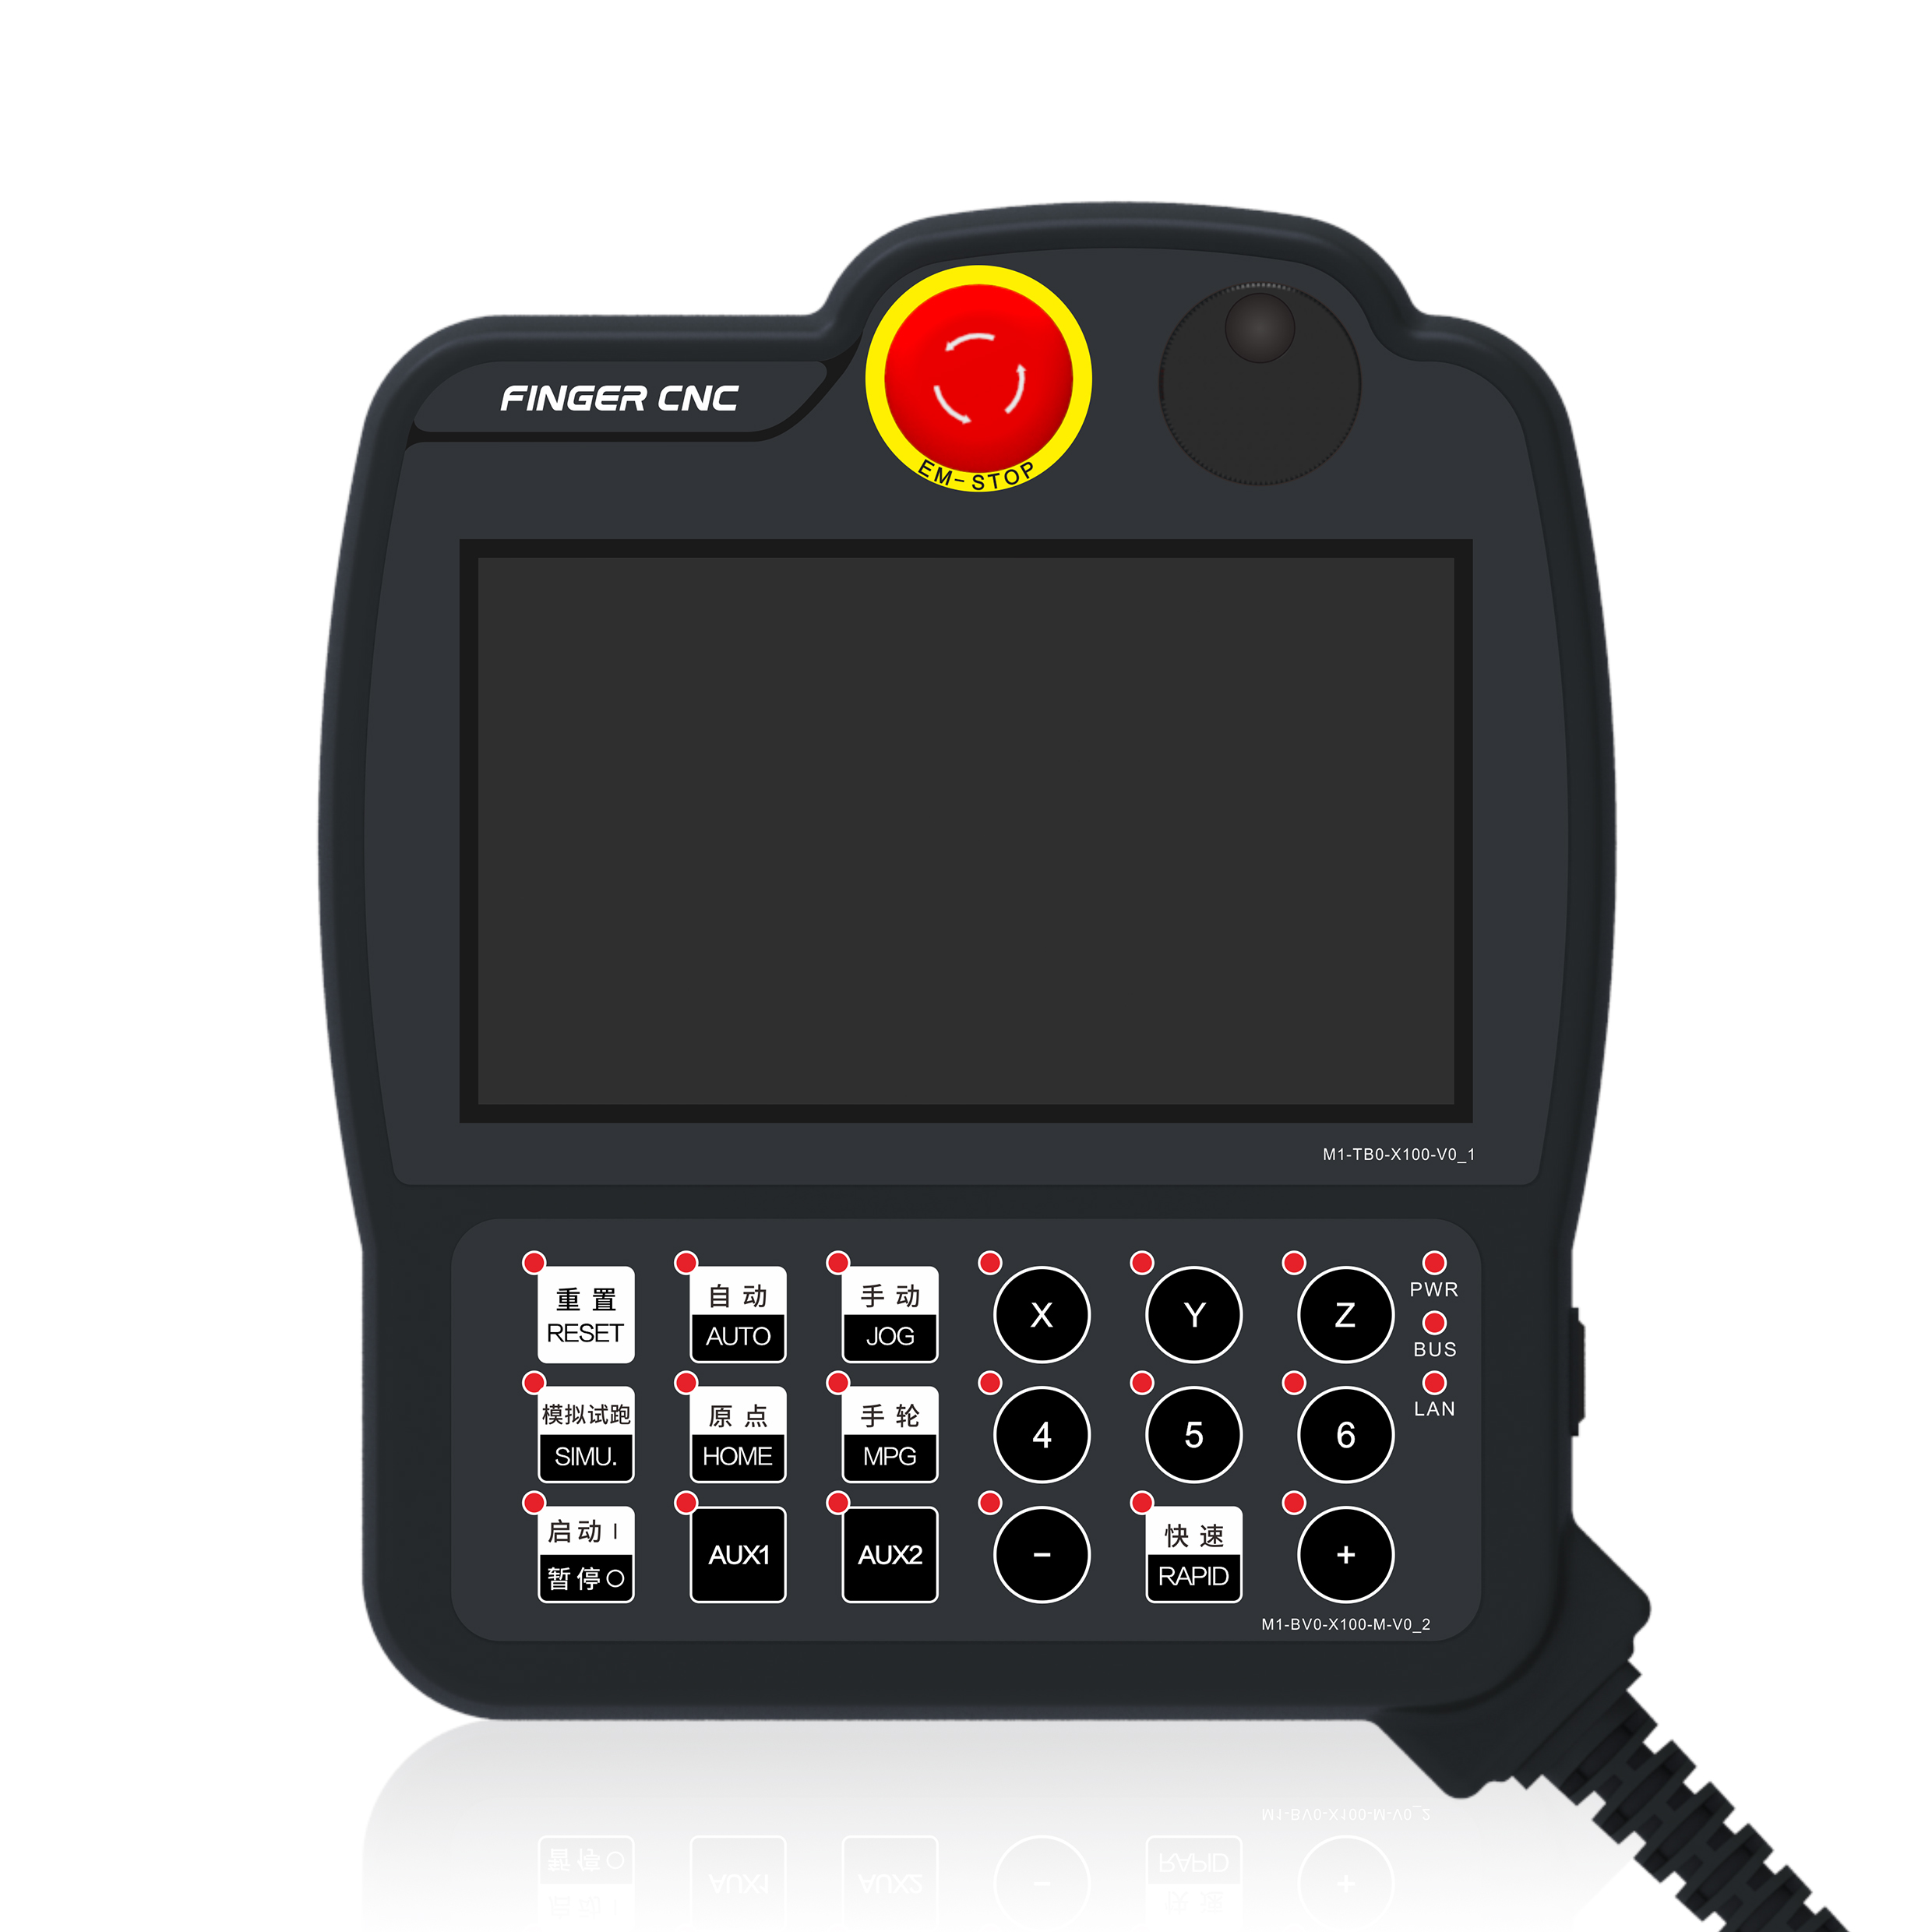
Dual-arm Gantry Robot Controller TP-X1-B-N-A2
2. EtherCAT bus communication, supports multiple EtherCAT slave expansions
3. Supports parallel invocation of multiple programs for efficient processing
4. Compatible with standard CNC MACRO calculations, and supports instruction and decimal point redefinition, making non-standard motion customization more convenient
5. IoT functionality supports a complete protocol gateway data acquisition system for big data analysis, providing the factory with data insights such as OEE indicators, equipment monitoring, maintenance, and statistical analysis; offers IoT solutions for various application scenarios, including discrete equipment, continuous equipment, local area network (LAN) solutions, and wide-area network (WAN) solutions.

Products Description
|
Product Series |
TP-X1-B-N-A1 |
TP-X1-B-N-A2 |
|
► System Specifications |
||
|
Display Size |
7-inch |
7-inch |
|
Maximum Number of Axes (Including Spindles) |
Standard 3 (max 9) |
Standard 6 (max 18) |
|
Maximum Number of Channels |
Standard 1 (max 1) |
Standard 2 (max 2) |
|
Maximum Number of Interpolated Axes per Channel |
9 |
9 |
|
Maximum Number of Spindles per Channel |
6 |
6 |
|
DA/AD |
External expansion module board (expandable to 32 groups) 14 BIT |
External expansion module board (expandable to 32 groups) 14 BIT |
|
Operating System |
RT Linux |
RT Linux |
|
Memory |
2GB |
2GB |
|
Program Capacity |
8GB |
8GB |
|
Block Pre-Reading Rate |
8000 b/s |
8000 b/s |
|
Maximum Tool Compensation Groups |
160 groups |
160 groups |
|
Communication |
USB/RS485/LAN/WIFI |
USB/RS485/LAN/WIFI |
|
Bus Function |
EtherCAT |
EtherCAT |
|
Maximum Expandable I/O |
256/256 (1ms 64 IN/OUT, 4ms 192 IN/OUT) |
256/256 (1ms 64 IN/OUT, 4ms 192 IN/OUT) |
|
Industrial IoT (IoT) |
Optional |
Optional |
|
Absolute Encoder Function |
SSI (6 groups, expandable up to 12 groups) |
SSI (6 groups, expandable up to 12 groups) |
|
► Compensation Functions |
||
|
Taper Compensation |
Supported |
Supported |
|
Backlash Compensation |
Supported |
Supported |
|
Arc Sharp Angle Compensation |
Supported |
Supported |
|
Bidirectional Leadscrew Error Compensation |
Supported |
Supported |
|
Feedforward Compensation |
Supported |
Supported |
|
► High-Speed and High-Precision |
||
|
NURBS Fitting |
Supported |
Supported |
|
Full Closed-Loop Control Function |
Supported |
Supported |
|
► Auxiliary Functions |
||
|
Custom Boot Screen |
Supported |
Supported |
|
Hybrid Use of Bus Axes and General-Purpose Axes |
Supported |
Supported |
|
IO Redefinition Function |
Supported |
Supported |
|
Inclined Axis Machining |
Supported |
Supported |
|
Inclined Plane Machining |
Supported |
Supported |
|
DNC Machining |
Supported |
Supported |
|
Proportional Scaling |
Supported |
Supported |
|
Acceleration/Deceleration Types |
Linear type (constant A), S type (constant JERK) |
Linear type (constant A), S type (constant JERK) |
|
Electronic Cam, PID Control |
Unlimited number of cam curves, each channel supports 16 sets of PID unwind/rewind controls |
Unlimited number of cam curves, each channel supports 16 sets of PID unwind/rewind controls |
|
MPG Feed Forward |
Supported |
Supported |
|
MPG Interrupt |
Supported |
Supported |
|
Multi-Function MPG |
Supported |
Supported |
|
Graphical Simulation |
Supported |
Supported |
|
Permission Management |
Supported |
Supported |
|
Perpetual Calendar Machine Lock |
Supported |
Supported |
|
Axis Load Monitoring |
Supported |
Supported |
|
Oscilloscope Function |
Supported |
Supported |
|
Following Error Detection |
Supported |
Supported |
|
Data Backup |
Supported |
Supported |
|
► Compound Functions |
||
|
Multi-channel functionality |
Supported |
Supported |
|
Independent channel control for robotic arms |
Supported |
Supported |
Hardware Overview
1.Input interface : Used to receive signals from external devices, such as key inputs from the machine tool operation panel, signals from various sensors (e.g., position sensors, temperature sensors), and CNC machining programs transmitted from external devices. Common input interface types include USB and Ethernet interfaces, facilitating connection and data transfer with different external devices.
2.Output interface : Outputs the control signals processed by the CNC system to the machine tool's execution components, such as drive motors, solenoid valves, and indicator lights, to control the machine tool's motion, actions, and status display. The signal types and formats need to match the connected execution components to ensure accurate signal transmission and execution.
3.7-inch touch screen : Used to display the CNC system's operation interface, machining programs, machining parameters, machine tool status, alarm information, and more, facilitating monitoring and operation by the operator.
4.Communication with external devices : Enables data transmission with upper-level devices (such as computers) to achieve remote monitoring, program transmission, system upgrades, etc.; or enables network communication with other CNC devices for coordinated work and centralized management of multiple devices.
5.High-performance CPU, serving as the core processing unit of the CNC system, responsible for processing and executing various CNC instructions, programs, and performing data calculations. The high-performance CPU can quickly respond to and process large amounts of instruction data, ensuring the system's real-time and efficient performance.
6.USB 3.0 port for convenient and fast program transfer during data import.
7.EtherCAT industrial fieldbus for high real-time response.
8.Expandable external function modules (ADC/DAC/AXES).

Software Overview
1.RT-Linux embedded control system platform
2.Fully compiled execution module
3.Configuration-based IoT development platform
4.Remote assistance for fault diagnosis and upgrades
5.Platform-based design concept
6.64-bit high-speed, high-precision contour control
7.Dialogue-based auxiliary program editing
8.Special curve processing: Supports constant speed processing of parabolic and spline curves, improving surface smoothness; the spline curve teaching function allows automatic fitting of curves between points using cubic equations, resulting in smoother curves than traditional teaching functions.
9.Supports dual-arm gantry, one-to-many gantry, and gantry structure.
10.Supports simultaneous parallel execution of multiple programs to achieve efficient processing.
11.IoT functionality supports a complete protocol gateway data acquisition system, providing big data analytics for factories, such as OEE indicators, equipment monitoring, maintenance, statistical analysis, etc.
12.IoT solutions for different application scenarios, including discrete equipment solutions, continuous equipment solutions, local network solutions, and wide-area network solutions.
13.Interference zone teaching: Automatically avoids when multiple arms enter, preventing simultaneous entry.
Product Features
1. Supports Dual-arm
2. Supports Internet of Things (IoT)
3. Supports Parallel Programming
4. Supports Simulation Test Run and Handwheel Prediction
5. Supports Customized Tray Handling
6. Customizable Safety Zone
7. Customizable IO Names
Application Cases
Truss robotic arm
Dimensions
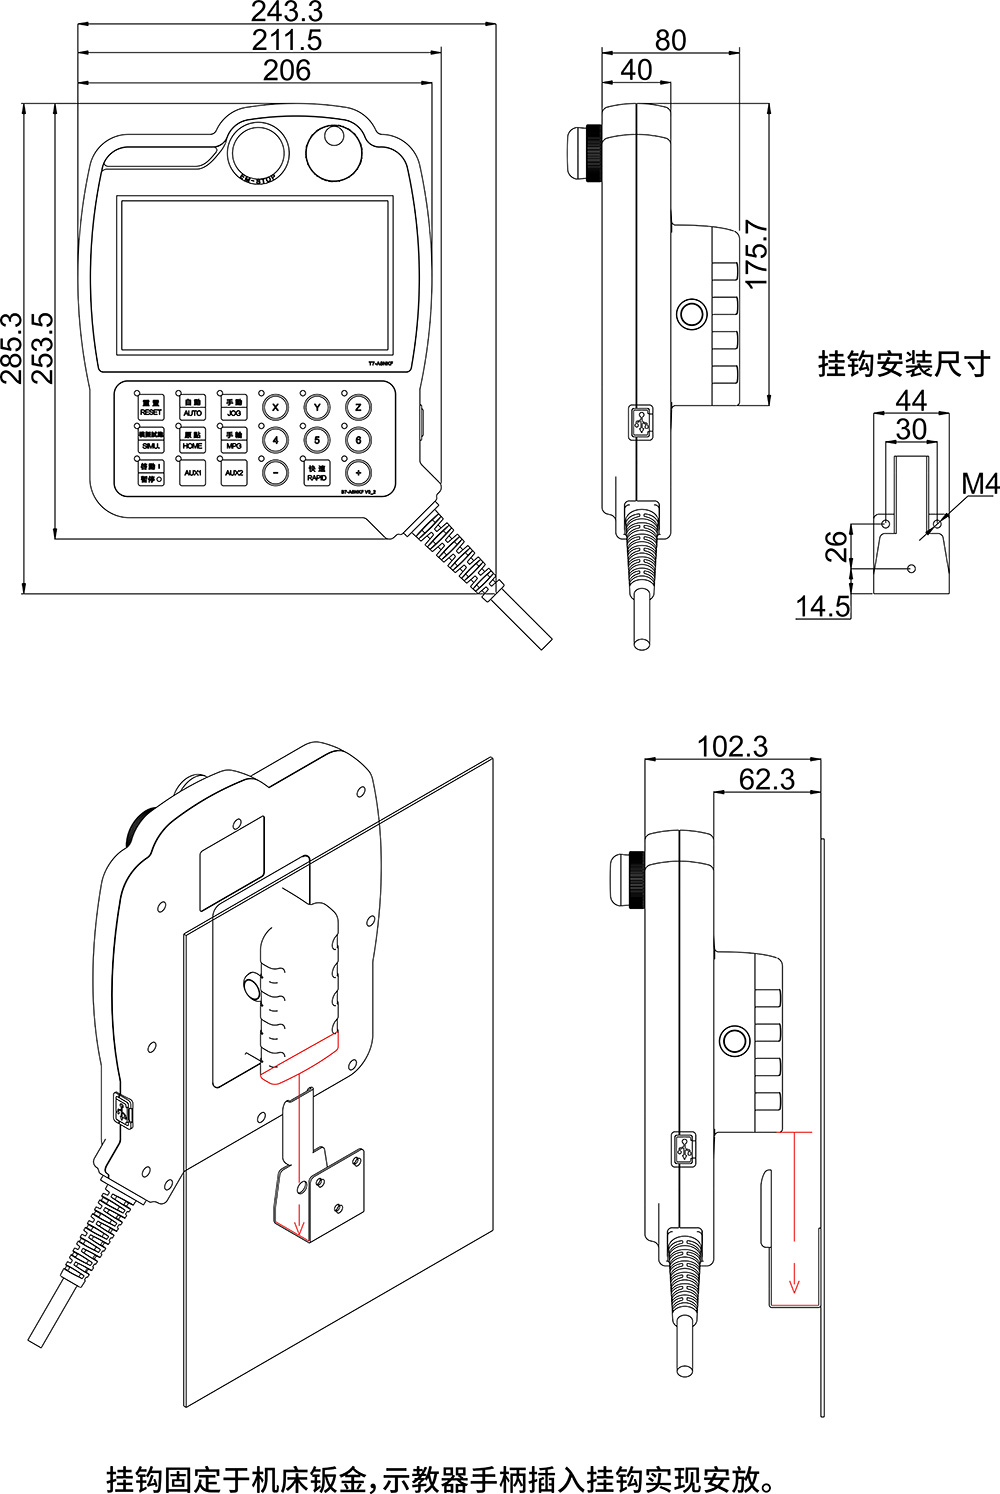
Hot Tags: Dual-arm Gantry Robot Controller TP-X1-B-N-A2, China Dual-arm Gantry Robot Controller TP-X1-B-N-A2 manufacturers, suppliers
Next
No InformationYou Might Also Like


Send Inquiry